Overview
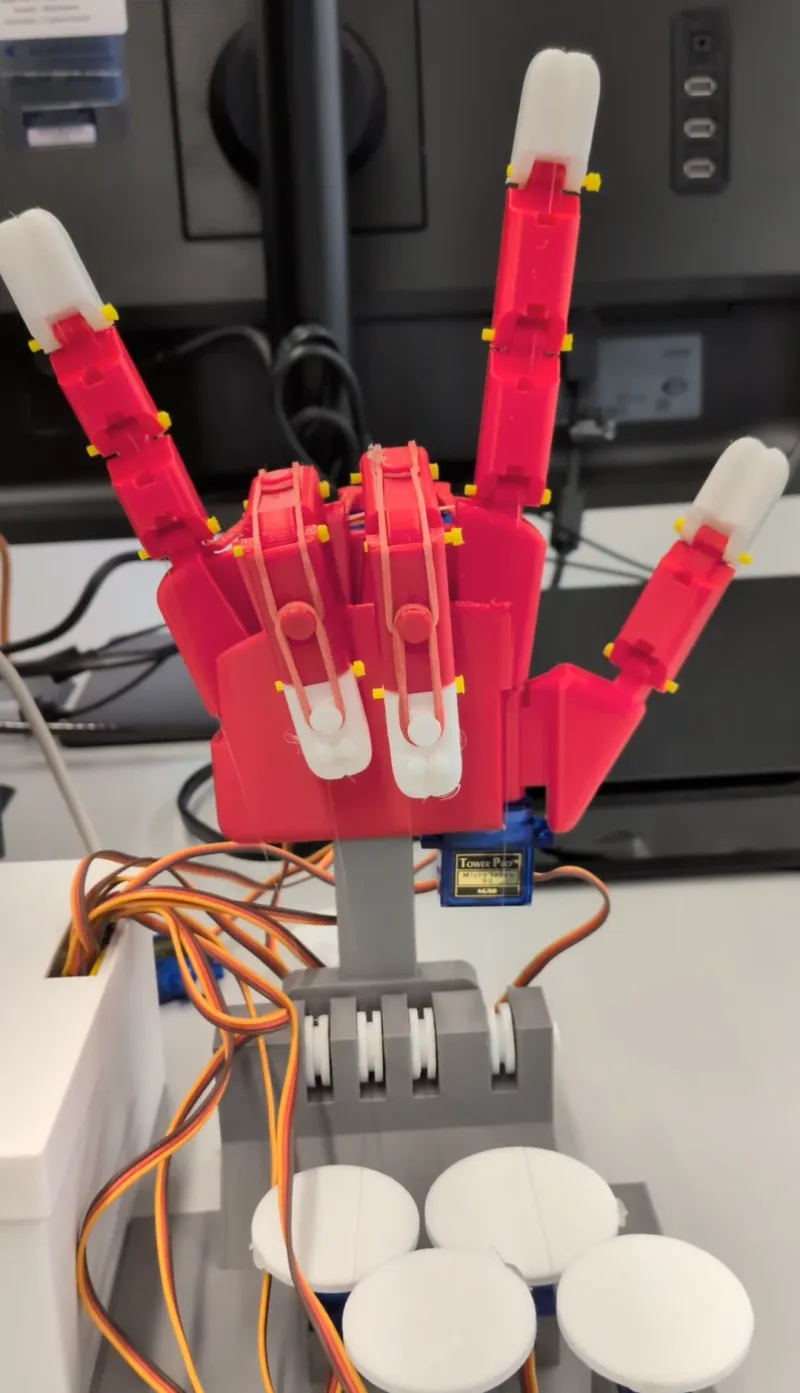
Handy Andy brings speech recognition and mechanical actuation together in a physical language interface. The project combines a pulley-driven hand with software that coordinates movement between signs.
Role and constraints
I led the cross-functional team as project manager and developed the Arduino C++ codebase, hardware interface, and pulley actuation mechanism.
Process
The prototype uses articulated fingers with servo-driven pulley actuation. I implemented smoothing algorithms to make transitions between hand positions more fluid.
Result
Built a robotic hand prototype connecting live English speech recognition with physical ASL hand movements.
Gallery